
Microrobot
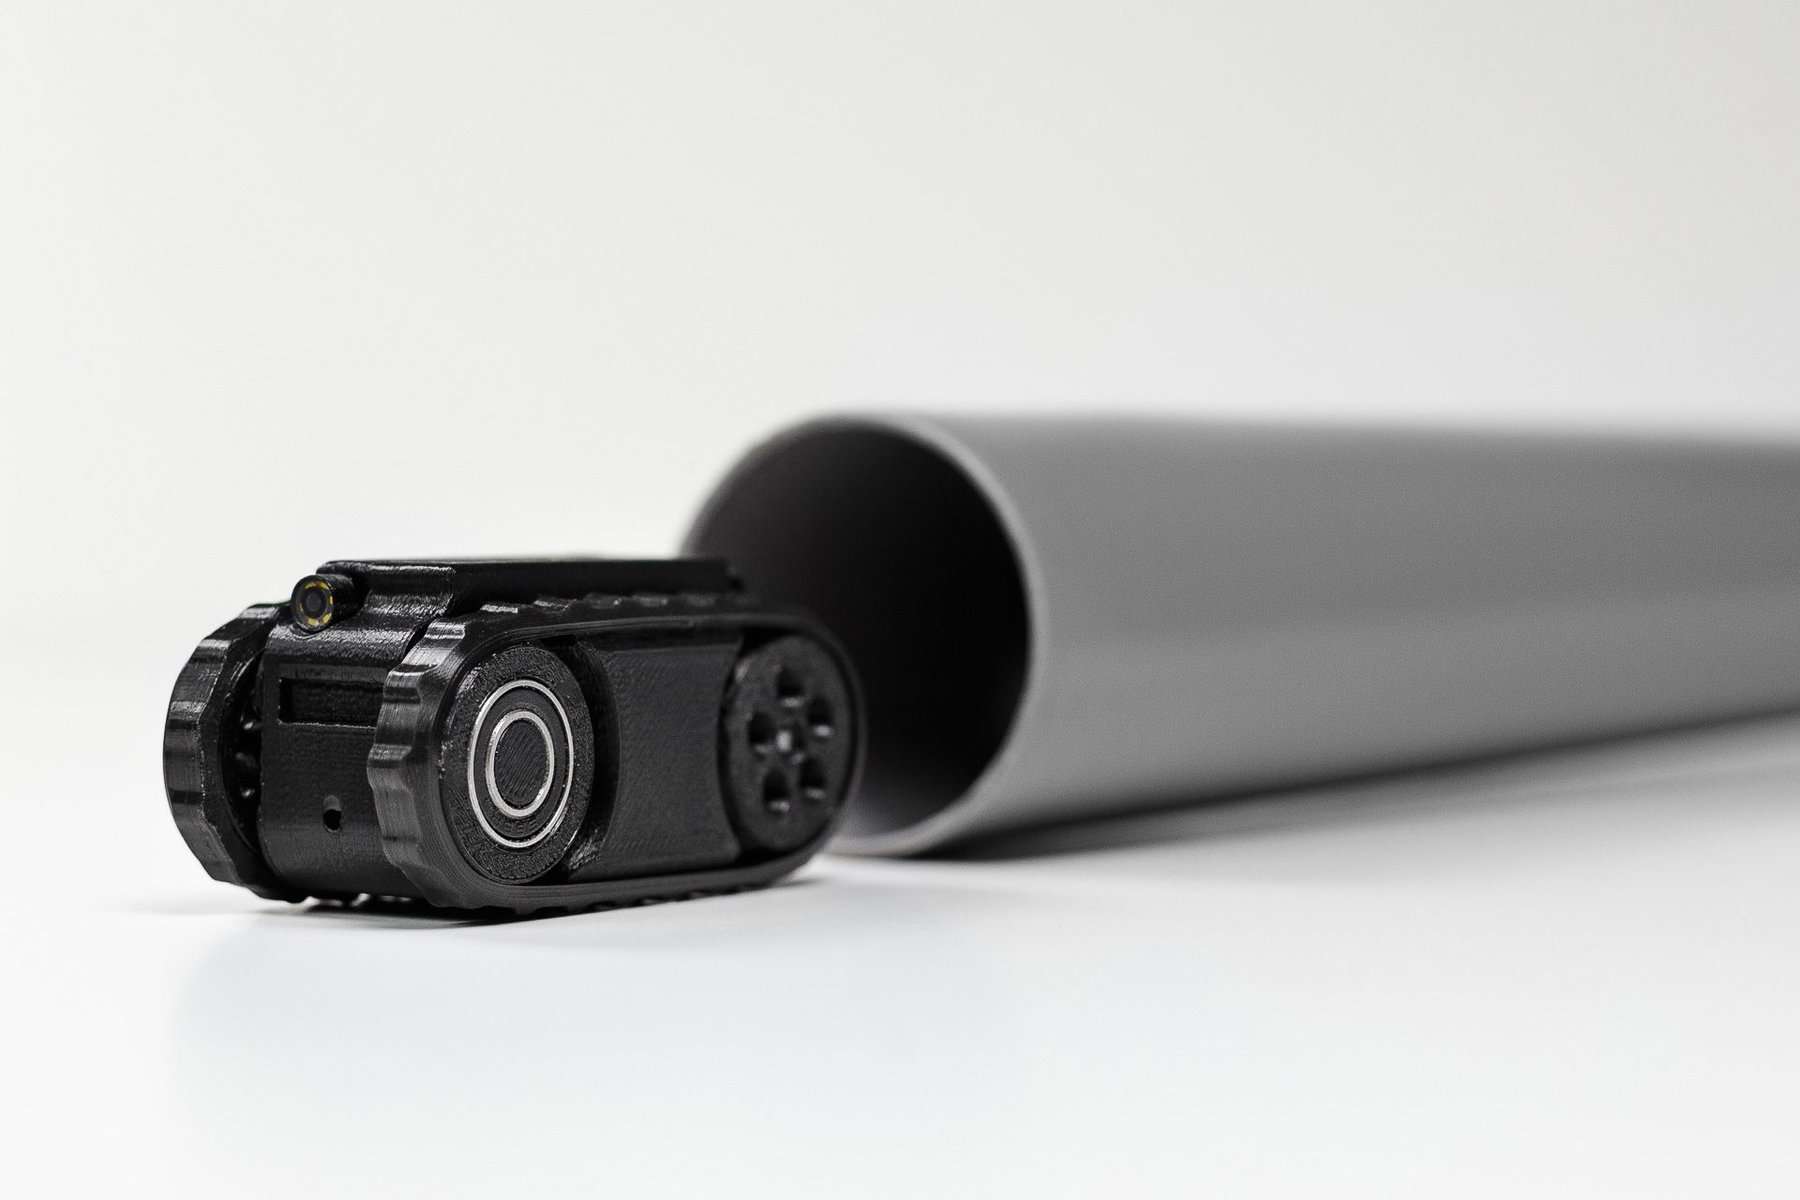
Caterpillar microrobot - a modern solution in miniaturized robotics
The tracked micro robot project is an innovative approach to remotely controlled, mobile systems that combine compact size with advanced functionality. The goal of the project is to design and build a tracked micro robot that offers users the ability to control it remotely, as well as transmit real-time video from two independent cameras to both a cell phone and a dedicated control station.
Thanks to its miniaturized components and advanced propulsion technology, the micro-robot will excel in environments where traditional solutions are too large or not precise enough. It can be used for field research, inspection of hard-to-reach areas, security tasks, and as a robotics education tool.
The micro-robot is equipped with a tracked drive that provides excellent traction on a variety of surfaces, and its specially designed dimensions allow it to move easily in narrow spaces. Two RGB cameras allow recording and transmission of images from the front and back of the robot, giving the operator full control over its movements. In addition, built-in LED lighting provides the ability to work in low-light conditions, enhancing the robot's functionality.
Remote control and video transmission One of the key advantages of the micro-robot is its ability to be controlled remotely via a cell phone or dedicated control station, with a range of up to 100 meters. Thanks to real-time image transmission from two cameras, the user has a full view of what is going on around the robot, which is especially important in tasks that require precise navigation or terrain monitoring.
Dedicated charging hangar The robot is equipped with a dedicated charging hangar, which allows the device to be conveniently and safely charged between work cycles. With this feature, the robot can be quickly prepared for the next tasks without the need for user intervention.
Compact design and mobility The micro-robot features extremely compact dimensions - 65 mm long, 35 mm wide and 34 mm high, making it one of the smallest robots in its class. This allows it to move in tight spaces, making it ideal for exploration missions or inspection of hard-to-reach areas. What's more, the robot is capable of climbing inclines of up to 30 degrees, further enhancing its mobility.
Resistance to environmental conditions Designed to operate in harsh environments, the microrobot can operate in a wide temperature range, from -20°C to +35°C, making it ideal for use in a variety of environments - both indoors and outdoors.
Working time and efficiency The micro-robot offers up to 15 minutes of continuous operation on a single charge, which is optimal for most tasks that require quick inspections and immediate access to data. The power technologies used and the efficiency of the drive make the robot efficient, and the operating time has been optimized for remote missions.
Technical specifications:
We are part of DroneSpaceValley.
More projects in Our Offer.
#MicroRobot #TrackedRobot #RemoteControl #ImageTransmission #RGB #LED Cameras #MobileRobotics #MiniaturizationTechnology #RobotForSpecialTasks. #SiteInspection #ControlRange #RobotForExploration #InnovationTechnology #RobotsForIndustry #MicroRobotText #MicroRoboticSystems #RobotsForMissions.
The tracked micro robot project is an innovative approach to remotely controlled, mobile systems that combine compact size with advanced functionality. The goal of the project is to design and build a tracked micro robot that offers users the ability to control it remotely, as well as transmit real-time video from two independent cameras to both a cell phone and a dedicated control station.
Thanks to its miniaturized components and advanced propulsion technology, the micro-robot will excel in environments where traditional solutions are too large or not precise enough. It can be used for field research, inspection of hard-to-reach areas, security tasks, and as a robotics education tool.
The micro-robot is equipped with a tracked drive that provides excellent traction on a variety of surfaces, and its specially designed dimensions allow it to move easily in narrow spaces. Two RGB cameras allow recording and transmission of images from the front and back of the robot, giving the operator full control over its movements. In addition, built-in LED lighting provides the ability to work in low-light conditions, enhancing the robot's functionality.
Remote control and video transmission One of the key advantages of the micro-robot is its ability to be controlled remotely via a cell phone or dedicated control station, with a range of up to 100 meters. Thanks to real-time image transmission from two cameras, the user has a full view of what is going on around the robot, which is especially important in tasks that require precise navigation or terrain monitoring.
Dedicated charging hangar The robot is equipped with a dedicated charging hangar, which allows the device to be conveniently and safely charged between work cycles. With this feature, the robot can be quickly prepared for the next tasks without the need for user intervention.
Compact design and mobility The micro-robot features extremely compact dimensions - 65 mm long, 35 mm wide and 34 mm high, making it one of the smallest robots in its class. This allows it to move in tight spaces, making it ideal for exploration missions or inspection of hard-to-reach areas. What's more, the robot is capable of climbing inclines of up to 30 degrees, further enhancing its mobility.
Resistance to environmental conditions Designed to operate in harsh environments, the microrobot can operate in a wide temperature range, from -20°C to +35°C, making it ideal for use in a variety of environments - both indoors and outdoors.
Working time and efficiency The micro-robot offers up to 15 minutes of continuous operation on a single charge, which is optimal for most tasks that require quick inspections and immediate access to data. The power technologies used and the efficiency of the drive make the robot efficient, and the operating time has been optimized for remote missions.
Technical specifications:
- Dimensions: 65 mm long, 35 mm wide, 34 mm high
- Drive: Caterpillar
- Cameras: 2 RGB cameras with LED lighting
- Control and transmission range: 100 m
- Operating temperature: from -20°C to +35°C
- Work time: Up to 15 minutes
- Climbing hills: up to 30 degrees
- Hangar: Dedicated charging hangar
We are part of DroneSpaceValley.
More projects in Our Offer.
#MicroRobot #TrackedRobot #RemoteControl #ImageTransmission #RGB #LED Cameras #MobileRobotics #MiniaturizationTechnology #RobotForSpecialTasks. #SiteInspection #ControlRange #RobotForExploration #InnovationTechnology #RobotsForIndustry #MicroRobotText #MicroRoboticSystems #RobotsForMissions.